Generalist locomotion via in-context learning
[Chainsaw vs. Robot]
[loss of limbs]
[blog]
I am a founding research scientist at Skild AI. I did my PhD at Carnegie Mellon University with Deepak Pathak. I am interested in building general-purpose, omni-bodied robot brains that work across tasks, environments, and robots.
I graduated from IIT Delhi with a B.Tech. in Computer Science and a President's Gold Medal (equivalent to valedictorian). In the past, I have been lucky to work with Prof. Mausam on neuro-symbolic AI and with Prof. Manik Varma on Extreme Classification. I have also had the good fortune of interning at Microsoft Research India where I worked with Dr. Ankit Garg on algebraic complexity. I also have a gold medal in the International Physics Olympiad (IPhO) in 2017.
Recent work at Skild AI
Press
Publications
-
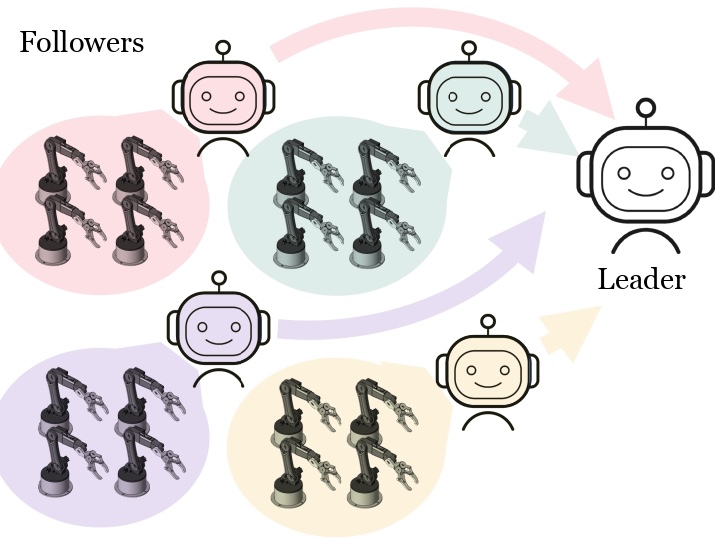
SAPG: Split and Aggregate Policy Gradients
Jayesh Singla*, Ananye Agarwal*, Deepak Pathak
ICML 2024, Oral [webpage] -
SPIN: Simultaneous Perception, Interaction and Navigation
Shagun Uppal, Ananye Agarwal, Haoyu Xiong, Kenneth Shaw, Deepak Pathak
CVPR 2024 [webpage] [arXiv] -
Dexterous Functional Grasping
Ananye Agarwal, Shagun Uppal, Kenneth Shaw, Deepak Pathak
CoRL 2023 [webpage] [arXiv] -
Extreme Parkour with Legged Robots
Xuxin Cheng*, Kexin Shi*, Ananye Agarwal, Deepak Pathak
ICRA 2024 [webpage] [arXiv] [code] -
LEAP Hand: Low-Cost, Efficient, and Anthropomorphic Hand for Robot Learning
Kenneth Shaw, Ananye Agarwal, Deepak Pathak
RSS 2023 [webpage] [paper] -
Legged Locomotion in Challenging Terrains using Egocentric Vision
Ananye Agarwal*, Ashish Kumar*, Jitendra Malik†, Deepak Pathak†
CoRL 2022, Best Systems Paper Award [webpage] [arXiv] [demo] [in the media] -
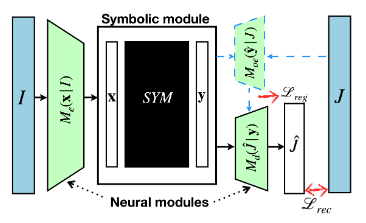
End-to-End Neuro-Symbolic Architecture for Image-to-Image Reasoning Tasks
Ananye Agarwal, Pradeep Shenoy, Mausam
[arXiv] -
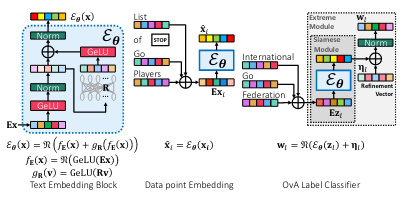
SiameseXML: Siamese networks meet extreme classifiers with 100M labels
K. Dahiya, A. Agarwal, D. Saini, K. Gururaj, J. Jiao, A. Singh, S. Agarwal, P. Kar and M. Varma
ICML 2021 [PDF] [code]
Live demos
Our small low-cost robot can perceive and traverse challenging terrain. This uses a single neural network running onboard that directly maps pixels to joint torques.
CoRL 2021, Auckland
CVPR 2021, New Orleans